Translation pending — read the English original while we localise.
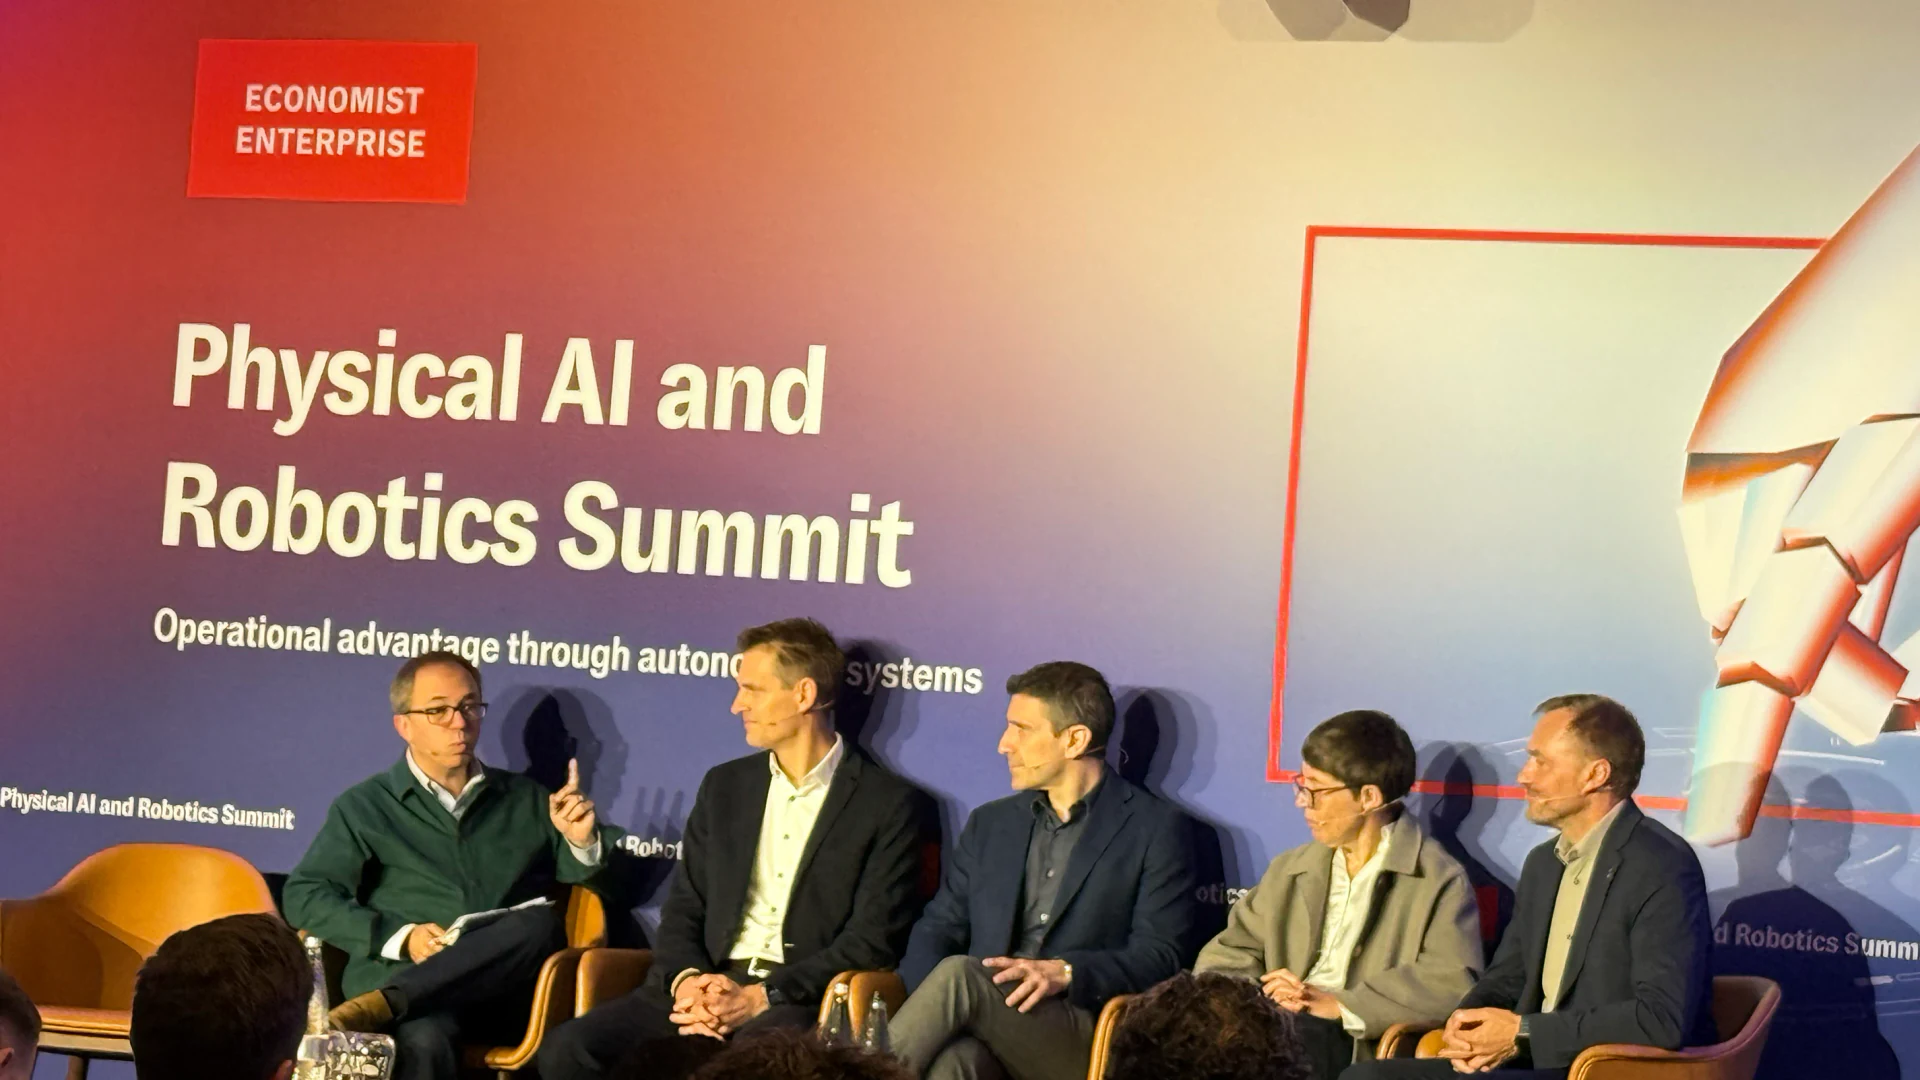
At the Economist Enterprise Physical AI and Robotics Summit held at Convene 200 Aldersgate in London on 13 October 2026, manufacturing executives, aerospace engineers, and roboticists gathered to address a fundamental schism in modern automation: should robots mimic the human body, or should mechanical morphology strictly follow industrial physics? While venture capital continues to pour billions into bipedal humanoid forms promising universal labour substitution, shop-floor practitioners from Airbus, Leonardo, and academic research delivered a stark, empirical reality check.
 .class="img-fluid clearfix"
The Anthropomorphic Trap: Questioning "Speciesist" Design #
During the morning panel session titled Two legs good? Putting the human in humanoid, moderated by Kenneth Cukier, Deputy Executive Editor at The Economist, the discussion immediately targeted the engineering assumptions underpinning contemporary humanoid robotics. Cukier provoked the panel by challenging the pervasive anthropocentric doctrine: why should an autonomous machine designed to fasten wing spars, route hydraulic conduits, or pick warehouse totes look like a human being?
Cukier characterised the unexamined assumption that intelligence requires a bipedal chassis and five-digit end-effectors as a form of engineering "speciesism". In biological evolution, the human form was not optimised for structural manufacturing, high-torque fastening, or continuous 24/7 duty cycles. Human physiology represents an evolutionary compromise balanced between energy conservation, bipedal locomotion over variable terrain, childbearing, and tool manipulation. Imposing those biological compromises on structural steel, harmonic drives, and brushless motors frequently degrades industrial performance.
Sebastian Jonas, leading manufacturing and automation programmes in aerospace, grounded the debate in operational reality. While acknowledging that historical factories were constructed around two-legged human ergonomics (door clearances, staircases, bench heights, and manual tooling stations), Jonas argued that attempting to deploy bipedal humanoids as drop-in replacements for human labour fundamentally misdiagnoses the bottleneck in modern manufacturing.
The primary constraint on modern assembly lines is not that robots cannot walk down the aisle; it is that rigid robotic actuators lack the compliance, micro-tactile sensing, and spatial reasoning required to manage non-rigid materials, variable tolerances, and unstructured assembly tasks.
The 10% Dividend: Why Incremental Automation Trumps 100% Lights-Out Visions #
A central insight shared by the aerospace leadership on stage was the stark contrast between public perception and actual factory automation rates. In commercial aerospace assembly, early-stage structural manufacturing remains astonishingly manual, with automation rates hovering around just 25%.
The reasons for this low baseline are physical rather than software-driven:
Non-rigid material handling. While pressing a stamped steel body panel in automotive spot-welding is straightforward, manipulating flexible composites, carbon-fibre plies, and elastomeric seals demands continuous tactile adjustment that rigid multi-axis industrial robots cannot deliver without elaborate, multi-million-pound custom end-effectors.
Cable harness routing and installation. In both aerospace and automotive manufacturing, routing wiring harnesses through tight airframe bulkheads or vehicle chassis remains almost 100% manual. Cables flex unpredictably; connectors require sensory feedback to seat properly; and clipping harnesses into blind brackets requires tactile confirmation that vision systems cannot verify.
Tolerance stack-up and blind fastening. Large-scale aerospace structures span dozens of metres. Thermal expansion, tooling wear, and material variances mean that every airframe differs by millimetres. Human mechanics instinctively compensate for tolerance stack-up by shifting alignment, tapping pins into place, and adjusting fastening angles. Current autonomous systems encounter torque faults when hole alignment drifts by fractions of a millimetre.
Sebastian Jonas emphasised that manufacturing executives must undergo a fundamental mindset shift. When engineering teams pursue 100% lights-out automation, the capital expenditure and systems complexity increase exponentially past the 80% mark. The final 15% to 20% of manual tasks consume 80% of the engineering budget and create 90% of line-down failure modes.
Instead, leading manufacturers are capturing massive enterprise value by targeting incremental 10% to 15% efficiency improvements. By deploying collaborative, task-specific robots that take over heavy lifting, repetitive drilling, and sealant application while keeping human artisans in the loop for complex routing and inspection, factories achieve double-digit productivity gains within months rather than waiting decades for fully autonomous general-purpose humanoid fleets.
Architectural Comparison: Humanoid Androids vs Functional Cobots #
The debate between anthropomorphic robotics and functional, task-optimised machines comes down to mechanical architecture, power density, and failure modes.
| Design Vector | Anthropomorphic Humanoid (Bipedal) | Functional Collaborative Robot (Cobot on Mobile Base) | Fixed Gantry / Articulated Automation Cell |
|---|---|---|---|
| Kinematic Architecture | 20 to 50+ degrees of freedom; serial kinematic chains; dual bipedal limbs | 6 to 7 DOF articulated arm mounted on omnidirectional wheeled AGV/AMR | 4 to 6 DOF Cartesian gantry or high-payload SCARA/6-axis arm |
| Locomotion Efficiency | Active dynamic balancing required at all times; high continuous baseline energy draw | Passive stability on multi-wheel base; near-zero energy consumption when stationary | Static floor or overhead rail mount; zero locomotion energy |
| Payload-to-Weight Ratio | Poor (typically 5 kg to 15 kg payload on a 60 kg to 85 kg chassis) | Moderate to high (10 kg to 25 kg payload on a 100 kg to 150 kg base) | Exceptional (50 kg to 1,500+ kg payload rigidly braced against foundation) |
| Positional Repeatability | Variable (2 mm to 10 mm under dynamic footfall conditions) | High (sub-millimetre, typically 0.03 mm to 0.1 mm with optical visual odometry) | Ultra-precise (0.01 mm to 0.05 mm mechanical repeatability) |
| Failure Envelope & Safety | Loss of balance leads to catastrophic falls; dynamic collapse hazard in shared human spaces | Low centre of mass; safety-rated monitored stop (ISO 10218-1/2); fails stationary | Physical fencing or light curtains; predictable, bounded hazard volume |
| Capital & Maintenance Cost | £150,000 to £350,000+; high wear on harmonic drives and balance actuators | £35,000 to £85,000; standard modular servomotors and swappable battery packs | £50,000 to £200,000; 10-year mean time between failures (MTBF) on hardened tracks |
| Brownfield Retrofit | High promise for stairs and narrow aisles; poor actual integration with legacy jigs | Requires ramps/flat floors; easily integrated alongside human workstations | Requires extensive structural line modifications and floor anchoring |
Source: Synthesis of Economist Enterprise Physical AI and Robotics Summit panel proceedings and aerospace manufacturing benchmarks (Convene 200 Aldersgate, London, 13 October 2026).
As the matrix illustrates, the engineering penalty for bipedal locomotion is severe. A bipedal humanoid must expend continuous electrical energy through its knee and ankle actuators merely to maintain balance while standing motionless in front of an assembly station. A wheeled mobile manipulator, by contrast, locks its wheel brakes, draws micro-watts of quiescent power, and channels all available battery energy into the high-torque end-effector performing useful work.
What This Means by Sector #
The operational balance between functional robotics and humanoid experimentation varies sharply across industrial domains.
Aerospace and Defence #
Aerospace assembly represents the most demanding physical manufacturing environment. With low production volumes (tens of aircraft per month rather than thousands of cars per day) and zero tolerance for structural defects, aerospace manufacturers cannot amortise rigid, single-purpose multi-million-pound transfer lines.
Airbus and Leonardo are focusing on "analogical flex" robotics: modular articulated arms deployed on automated guided platforms that traverse fuselage sections, lock rigidly onto airframe locating pins via vacuum or magnetic clamps, and execute precision drilling, countersinking, and sealant dispensing. Human mechanics work alongside these units, performing wire-bundle installation, hydraulic line connection, and final structural quality sign-offs. General-purpose bipedal humanoids remain confined to laboratory trials, with zero production-critical flight hardware currently dependent on them.
Automotive and Battery Manufacturing #
Automotive body shops already operate at 90% to 95% automation using heavy industrial 6-axis arms for stamping, spot-welding, and painting. The remaining manual domain is final assembly (trim, chassis, and electronics installation).
Automotive OEMs are testing humanoids primarily for line-side kitting and parts sequencing: walking to racking aisles, picking plastic totes, and placing them onto mobile carts. However, internal benchmarks reveal that automated vertical storage systems (ASRS) paired with conventional roller conveyors achieve five times the throughput at one-third of the operational cost. The industry's primary near-term automation investments are flowing into intelligent vision-guided cobots for underbody bolting, battery pack sealing, and windscreen placement.
Discrete Electronics and Appliance Assembly #
In consumer electronics and household appliance manufacturing, product lifecycles are measured in months rather than decades. Factories in Shenzhen and Eastern Europe have demonstrated that reconfigurable cobot workstations with standardized quick-change grippers allow production lines to retool in hours.
The push towards sub-$200 open-source robotic arms and vision-based imitation learning (such as Hugging Face LeRobot) is providing small and medium-sized manufacturers with automated assembly capabilities that previously required bespoke industrial automation integrators. Here, physical morphology is strictly dictated by the component: vacuum suction cups for glass displays, pneumatic parallel grippers for circuit boards, and magnetic pickups for transformer cores.
The "Analogical Flex" Concept: Engineering the Intermediate Era #
A critical technical concept articulated during the summit was "analogical flex" robotics. Rather than assuming that factories must either remain entirely dependent on manual labour or undergo immediate full-scale robotic rebuilds, the analogical flex philosophy establishes an intermediate technological layer.
Under this paradigm, autonomous cobots are engineered to adapt to existing human tools and fixtures:
- Tool-independent actuation: Instead of requiring digital bus connections to every shop-floor tool, robots utilise standard pneumatic torque wrenches, rivet guns, and adhesive guns through ergonomic adapters.
- Visual-tactile co-pilot architectures: Machine-vision models observe the human artisan performing a complex operation (such as routing a hydraulic pipe through an engine pylon), record the trajectory, and infer the force thresholds applied. The robot then handles the physical support and torque application on subsequent assemblies, while the human guides the alignment.
- Brownfield sensor retrofitting: Rather than equipping the robot with extreme on-board compute to map an unstructured world in real time, low-cost optical fiducials (AprilTags) and overhead ultra-wideband (UWB) tracking beacons are placed on existing assembly jigs. This provides the robot with millimetre-accurate positional awareness without requiring complex SLAM algorithms.
This approach acknowledges that modern manufacturing infrastructure has trillions of dollars invested in tooling, fixtures, and certification documentation. A technology that requires replacing those certified fixtures with humanoid-friendly environments faces an impossible capital barrier; a technology that seamlessly clamps into existing tooling wins the commercial race.
Conclusion #
The lively debate between Kenneth Cukier and Sebastian Jonas at the Economist Enterprise Physical AI and Robotics Summit exposed the crucial dividing line between silicon-valley aspiration and industrial ground truth.
Humanoid robots will continue to capture public imagination and drive venture capital valuations, providing an exceptional testbed for multi-contact locomotion, whole-body trajectory optimisation, and generalized dexterity. But on the factory floor, where operating margins, overall equipment effectiveness (OEE), and takt times dictate enterprise survival, the laws of physics and economics remain sovereign.
The future of high-performance manufacturing is not a workforce of two-legged mechanical androids holding spanners. It is an intelligently orchestrated ecosystem of rigid gantries, high-speed mobile manipulators, and flexible collaborative tools designed to relieve human workers of physical strain while amplifying human dexterity. Form must follow function. In the race for industrial operational advantage, the machine that wins is never the one that looks the most human; it is the one that delivers zero defects, continuous uptime, and measurable return on invested capital.
Frequently Asked Questions #
Why are bipedal humanoid robots less efficient than wheeled robots in factories? Bipedal robots require continuous active balance control, constantly firing servomotors in their ankles, knees, and hips even when standing still. Wheeled automated guided vehicles (AGVs) and autonomous mobile robots (AMRs) possess passive mechanical stability. When stationary, wheeled bases lock their brakes and consume negligible idle power, directing all battery reserves to the robotic manipulator. Furthermore, wheeled bases provide a much more rigid and stable platform for high-torque fastening and precision assembly.
What percentage of aerospace assembly is currently automated? Early-stage aerospace structural assembly is currently only approximately 25% automated. The remaining 75% remains manual due to the high flexibility of composite and sheet metal parts, complex blind fastening inside confined fuselage spaces, and intricate wire harness routing that demands real-time tactile compliance and human judgement.
Why is 100% lights-out automation considered an economic fallacy in discrete manufacturing? In manufacturing systems engineering, the cost and technical complexity of automation rise exponentially as a process approaches 100% autonomy. Automating the initial 70% to 80% of repetitive, rigid operations is economically viable. However, automating the remaining 20% of flexible, irregular, and exception-handling tasks requires disproportionate capital expenditure and creates fragile systems prone to frequent downtime. Striving for incremental 10% to 15% gains through human-in-the-loop collaboration yields far higher return on invested capital.
What are "analogical flex" robots? Analogical flex robots are hybrid, adaptive robotic systems engineered to serve as an interface between traditional, human-centric manufacturing environments and future autonomous factories. Instead of requiring completely redesigned robotic plants, these systems clamp into existing assembly fixtures, use standard industrial hand tools, and operate collaboratively alongside human mechanics to absorb physical fatigue while relying on human oversight for complex verification.
How does tactile compliance limit current robotic assembly? Most industrial robotic arms operate on position control: they move to exact Cartesian coordinates with extreme rigidity. However, tasks like threading a bolt into a tapped hole or fitting a cable grommet require force compliance, where the actuator yields slightly in response to contact forces to avoid cross-threading or part damage. While force-torque sensors and compliant impedance control have advanced, they remain significantly slower and less reliable than the human hand's biological tactile feedback.
References #
- Economist Enterprise, (2026). Physical AI & Robotics Summit: Operational advantage through autonomous systems ⧉. Economist Enterprise.
- Economist Enterprise, (2026). Physical AI & Robotics Summit Agenda: Two legs good? Putting the human in humanoid ⧉. Economist Enterprise.
- Cukier, K., (2026). Challenging Anthropomorphic Bias in Autonomous Robotics ⧉. The Economist.
- Jonas, S., (2026). Pragmatic Automation in Aerospace Structural Assembly: Lessons from the Shop Floor ⧉. Airbus Industrial Operations.
- International Organization for Standardization, (2026). ISO 10218-1:2026 Robots and robotic devices - Safety requirements for industrial robots ⧉. ISO.
- International Organization for Standardization, (2026). ISO/TS 15066:2026 Robots and robotic devices - Collaborative robots ⧉. ISO.
- Bogue, R., (2026). The Economics of Humanoid versus Wheeled Mobile Manipulation in Industrial Plants ⧉. Industrial Robot: the international journal of robotics research and application.
最近審閱 .
最近審閱 .
轉載本文
複製 Medium 格式
# Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau

> Originally published at [https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/](https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/)

At the Economist Enterprise Physical AI and Robotics Summit in London, aerospace and automation leaders challenged the humanoid robotics hype. Discover why 100% lights-out automation remains an industrial fallacy, why 10% incremental productivity with humans-in-the-loop delivers immediate returns, and how functional morphology outperforms bipedal mimicry in aerospace and automotive assembly.

Read the full article on sebastienrousseau.com: https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/
複製 Mastodon 格式
Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau

At the Economist Enterprise Physical AI and Robotics Summit in London, aerospace and automation leaders challenged the humanoid robotics hype. Discover why 100% lights-out automation remains an industrial fallacy, why 10% incremental productivity with humans-in-the-loop delivers immediate returns, a…

https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/
複製 LinkedIn 格式
Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau

At the Economist Enterprise Physical AI and Robotics Summit in London, aerospace and automation leaders challenged the humanoid robotics hype.

以下是關鍵策略要點:

- The Anthropomorphic Trap: Questioning "Speciesist" Design. During the morning panel session titled Two legs good?
- The 10% Dividend: Why Incremental Automation Trumps 100% Lights-Out Visions. A central insight shared by the aerospace leadership on stage was the stark contrast between public perception and actual factory automation rates.
- Architectural Comparison: Humanoid Androids vs Functional Cobots. The debate between anthropomorphic robotics and functional, task-optimised machines comes down to mechanical architecture, power density, and failure modes.
- What This Means by Sector. The operational balance between functional robotics and humanoid experimentation varies sharply across industrial domains.

貴組織如何應對本文所述的挑戰?

→ https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/

#HumanoidRobotics #FunctionalRobotics #ManufacturingAutomation #AerospaceAssembly #PhysicalAi

Sebastien Rousseau | CC-BY-4.0
引用本文
Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau
At the Economist Enterprise Physical AI and Robotics Summit in London, aerospace and automation leaders challenged the humanoid robotics hype. Discover why 100% lights-out automation remains an industrial fallacy, why 10% incremental productivity with humans-in-the-loop delivers immediate returns, and how functional morphology outperforms bipedal mimicry in aerospace and automotive assembly.
BibTeX
@online{rousseau2026humanoid,
  author  = {Rousseau, Sebastien},
  title   = {{Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau}},
  year    = {2026},
  url     = {https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/},
  urldate = {2026}
}RIS
TY  - GEN
AU  - Rousseau, Sebastien
TI  - Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau
PY  - 2026
UR  - https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/
ER  -
Vancouver
Rousseau S. Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau. sebastienrousseau.com. 2026 Oct 13. Available from: https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/
Chicago
Rousseau, Sebastien. "Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau." sebastienrousseau.com. October 13, 2026. https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/.
APA
Rousseau, S. (2026, October 13). Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau. sebastienrousseau.com. https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/
重新發佈本文
Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau
At the Economist Enterprise Physical AI and Robotics Summit in London, aerospace and automation leaders challenged the humanoid robotics hype. Discover why 100% lights-out automation remains an industrial fallacy, why 10% incremental productivity with humans-in-the-loop delivers immediate returns, and how functional morphology outperforms bipedal mimicry in aerospace and automotive assembly.
本文採用以下授權條款 Creative Commons Attribution 4.0 International. 重新發佈需註明原始 URL 出處。
Humanoid vs Functional Robotics in Manufacturing Automation: Why Form Follows Function on the Factory Floor — Sebastien Rousseau

At the Economist Enterprise Physical AI and Robotics Summit in London, aerospace and automation leaders challenged the humanoid robotics hype. Discover why 100% lights-out automation remains an industrial fallacy, why 10% incremental productivity with humans-in-the-loop delivers immediate returns, and how functional morphology outperforms bipedal mimicry in aerospace and automotive assembly.

Originally published at https://sebastienrousseau.com/zh-hant/2026-10-13-humanoid-vs-functional-robotics-in-manufacturing-tw/ by Sebastien Rousseau.
Licensed under CC-BY-4.0.